Zephyr Runtime PM Dependencies: Holding a Sensor Does Not Hold Its I2C Bus
Why can an I2C controller suspend between transactions while a sensor remains runtime-active, even though power-domain acquisition is automatic?
Firmware requirements, peripheral integration, task coordination, fault diagnosis and verification for microcontroller products. Start from the actual hardware and acceptance conditions before choosing an implementation.
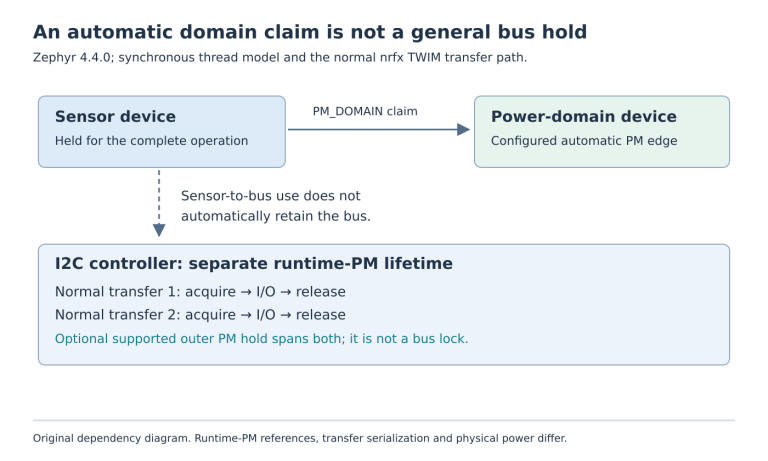
Why can an I2C controller suspend between transactions while a sensor remains runtime-active, even though power-domain acquisition is automatic?
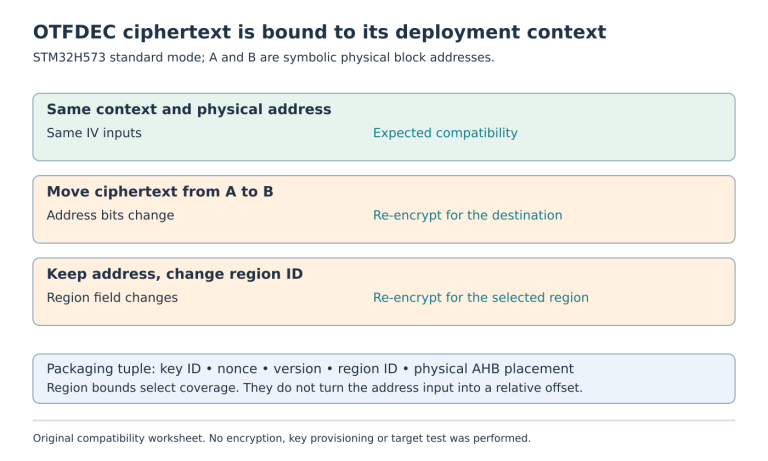
Why does an encrypted external-flash image stop decrypting correctly after relocation even when its key and nonce are unchanged?
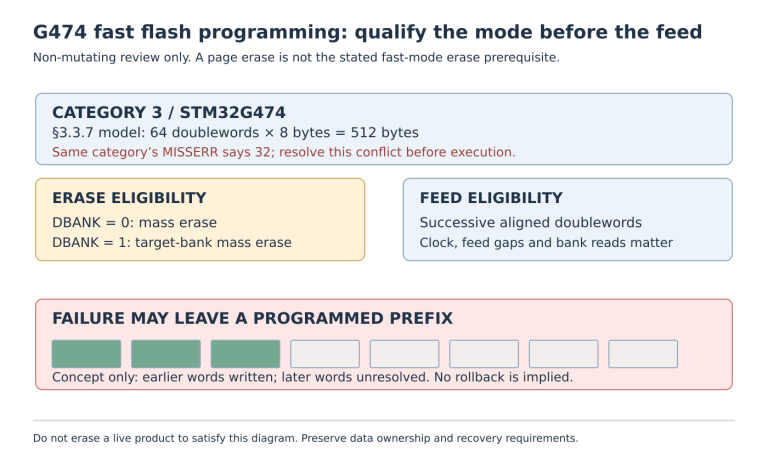
Why can G474 fast programming fail after a page erase or stop partway through a seemingly valid block, although ordinary doubleword programming works?
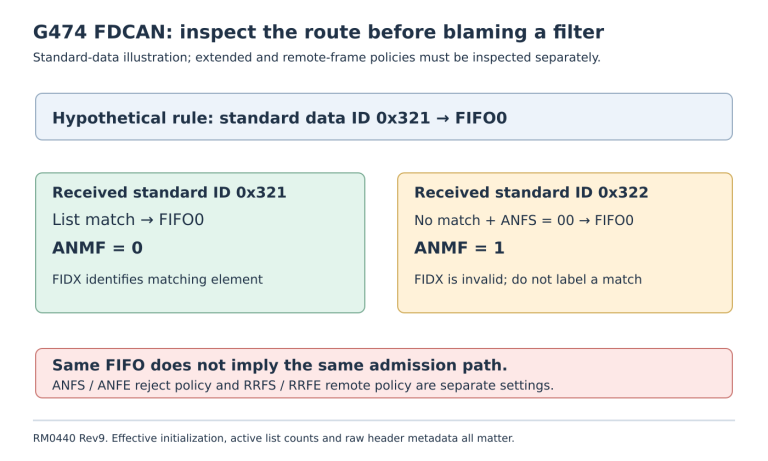
Why do unrelated CAN identifiers still reach G474 FIFO0 after firmware installs a narrow acceptance filter?
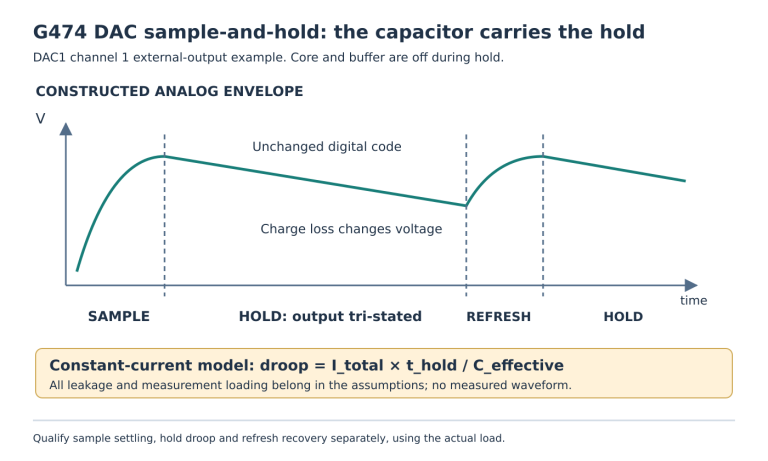
Why does a G474 DAC output drift in sample-and-hold mode even when firmware never changes its digital code?
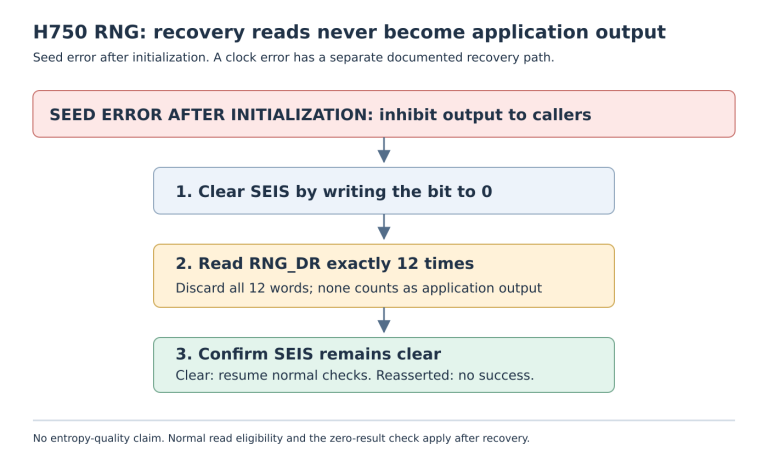
Why is clearing SEIS insufficient to resume an H750 random-number API safely after a seed error?
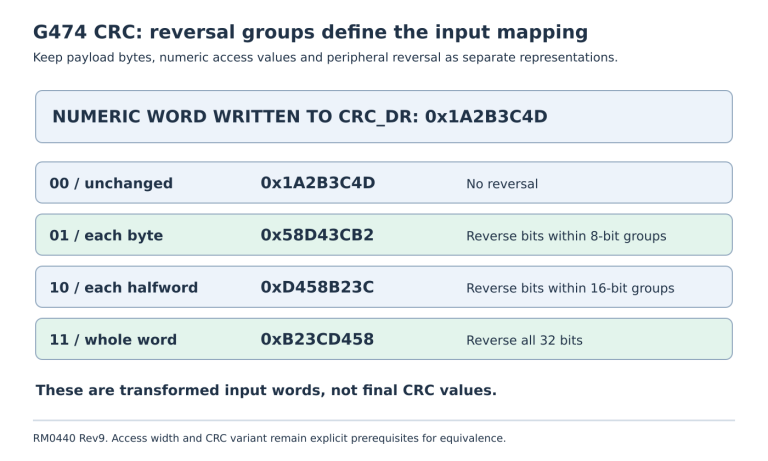
Why does a G474 hardware CRC change when firmware replaces byte writes with packed word writes even though the payload bytes are unchanged?
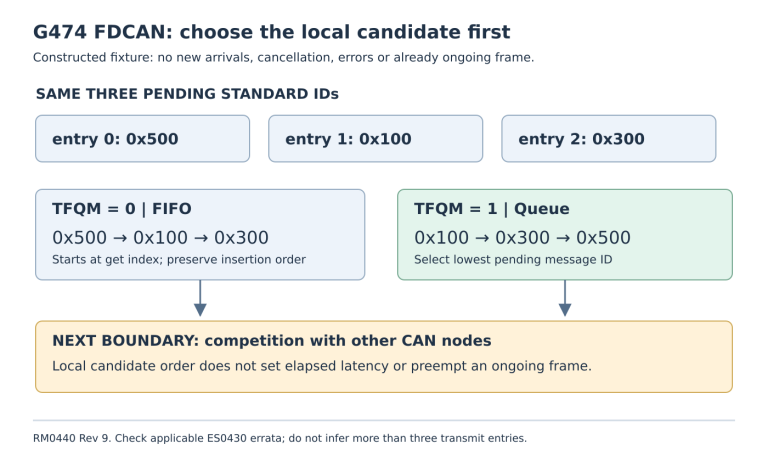
Why can a later low-ID frame wait behind an earlier high-ID frame in one G474 configuration but overtake it in another?
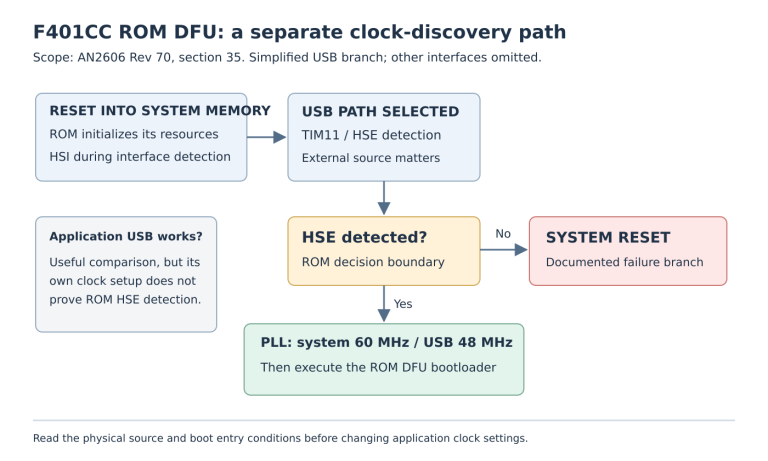
Why can USB work in an STM32F401CCU6 application while its ROM DFU path resets or never enumerates?
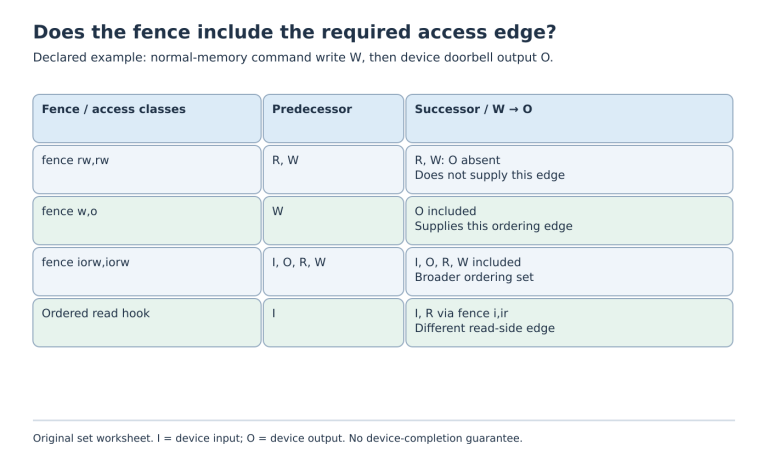
Why does a RAM-only fence fail to establish a normal-memory-to-device ordering edge, and what changes between relaxed and ordered Linux RISC-V MMIO accessors?