Zephyr OS Modules: Trace Missing Kconfig and CMake Integration from module.yml
Trace module recognition, Kconfig inclusion and CMake source inclusion before diagnosing runtime behavior.
Firmware requirements, peripheral integration, task coordination, fault diagnosis and verification for microcontroller products. Start from the actual hardware and acceptance conditions before choosing an implementation.
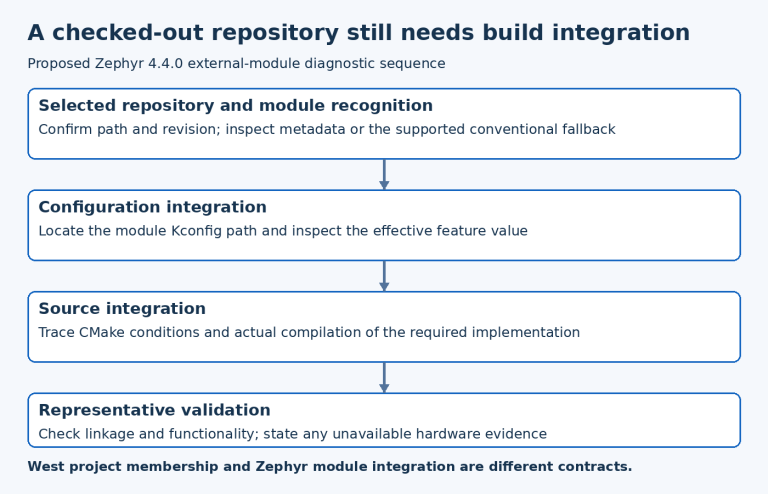
Trace module recognition, Kconfig inclusion and CMake source inclusion before diagnosing runtime behavior.
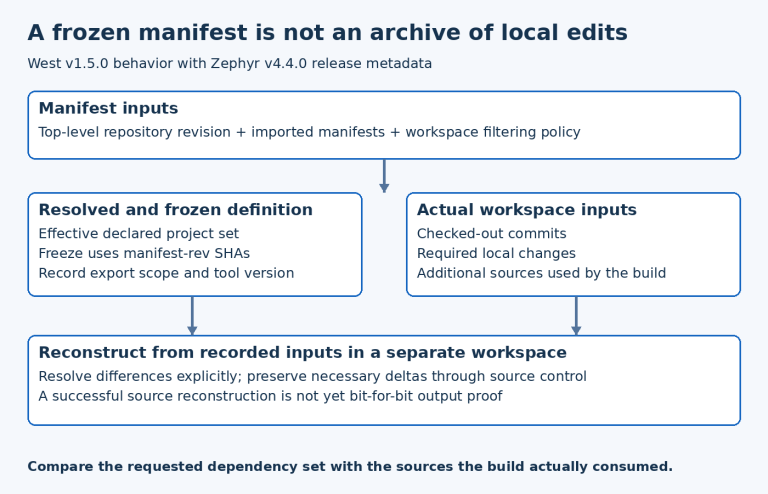
Compare resolved manifest dependencies with actual checkout commits and local changes before claiming source reproducibility.
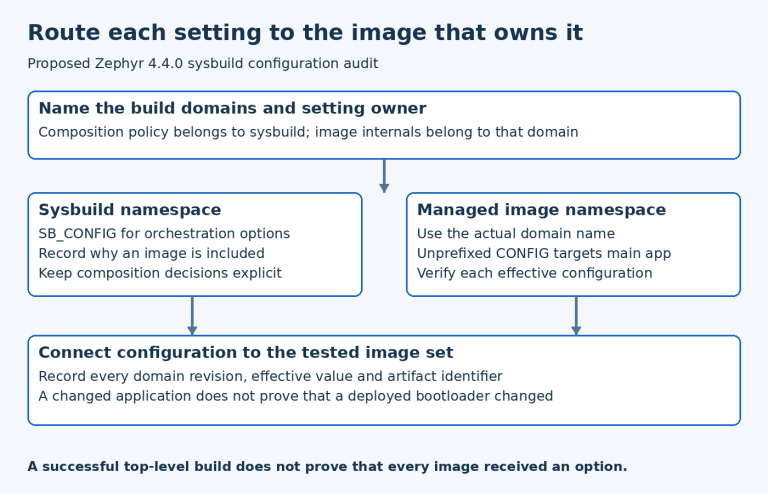
Verify sysbuild, main-application and additional-domain settings in the correct effective configuration.
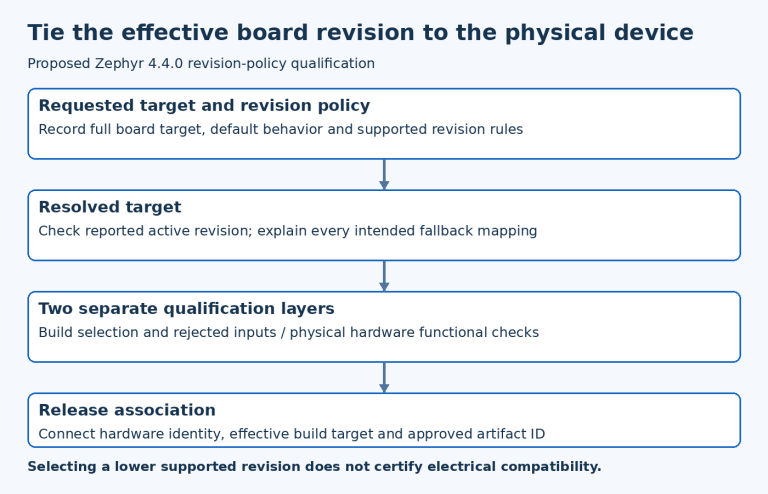
Audit defaults, exact matching and fallback revision selection before associating an image with physical hardware.
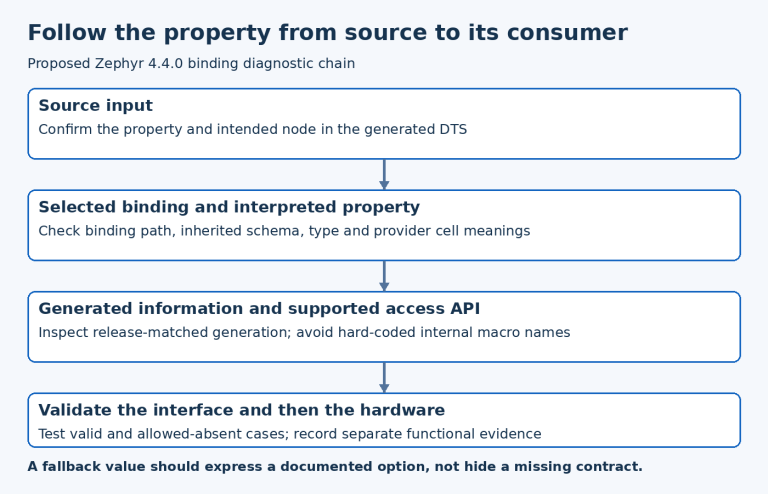
Diagnose missing generated devicetree information through binding selection, property schema and the consumer access pattern.
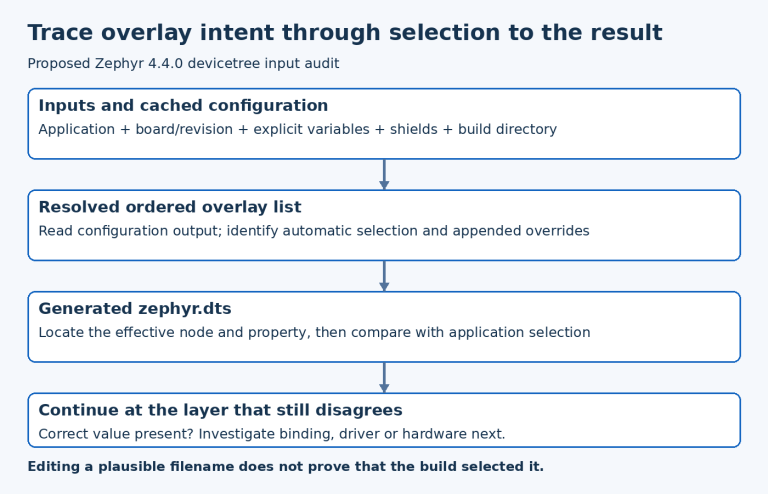
Diagnose an ineffective overlay using resolved inputs, cache evidence, override ordering and the generated DTS.
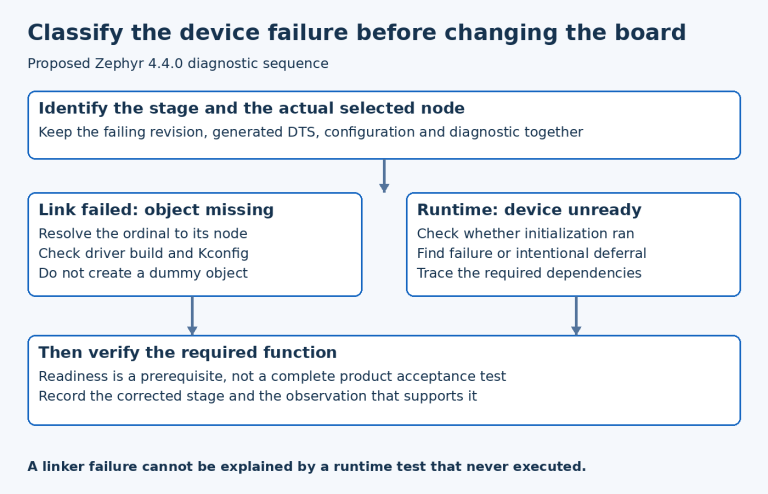
Separate missing driver objects at link time from unready devices after startup, then verify the required function.
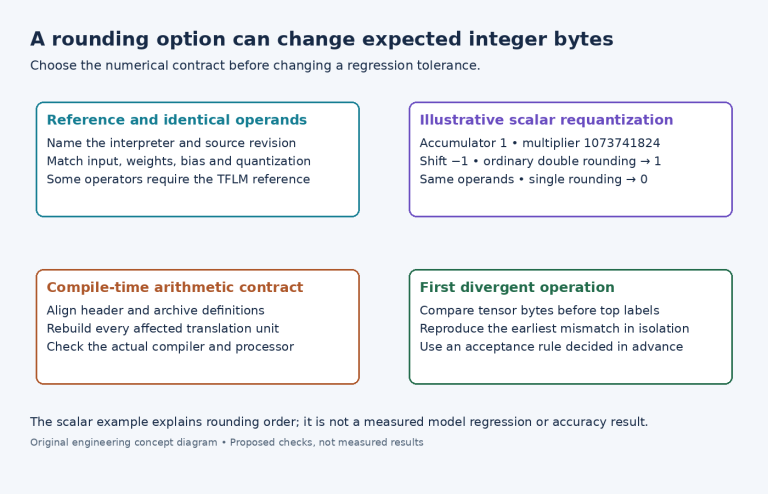
Separate CMSIS-NN numerical configuration from genuine regressions by selecting the correct reference, matching rounding options and reproducing the first divergent operation.
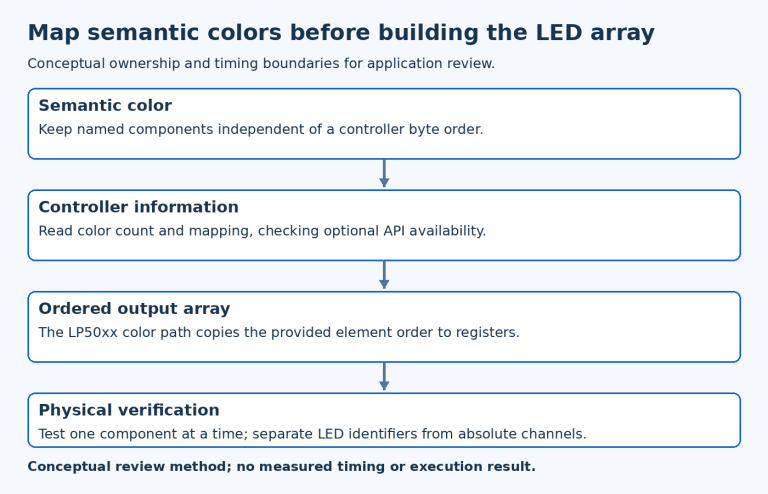
Map semantic colors before building the LED array. Versioned implementation and integration review.
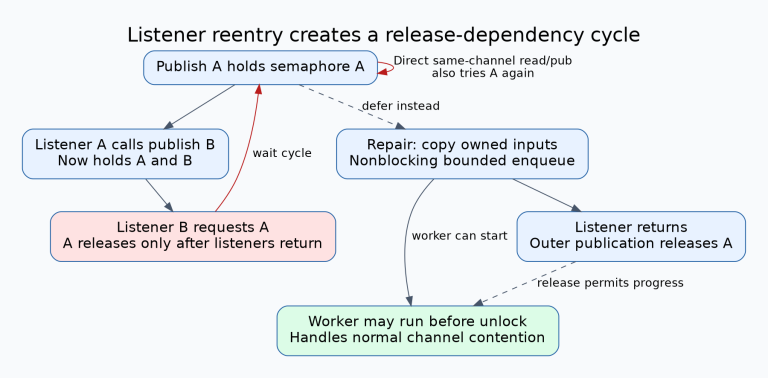
A zbus listener must not wait for a channel whose release depends on that listener returning. In the same-channel case, a nested locking read or publication can wait on the semaphore already held by its outer publication. Across channels, listener chains can form the same dependency cycle. Draw the nested call graph before changing timeout…